FB_MTP_MonAnaVlv
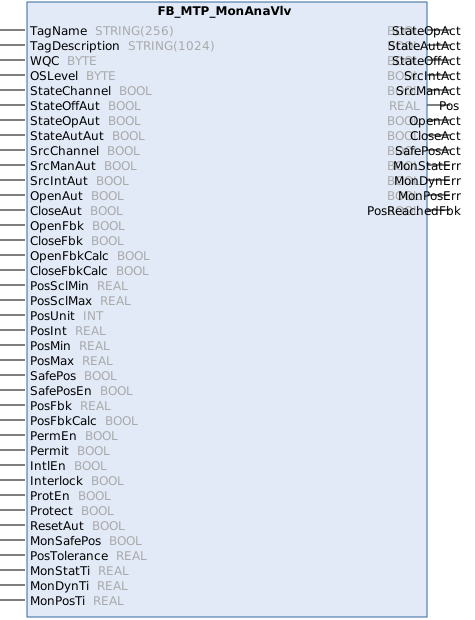
The function block FB_MTP_MonAnaVlv is an object for controlling an analog valve from different sources: internal PLC logic or manual operation (access via OPC UA). Switching requests and value specifications are managed independently of each other via the state machines Operation Mode and Source Mode. It also includes the option of monitoring the output values with the respective feedback signals. The OPC UA access rights are described in the variable tables.
Controlling the valve
The specification for opening and closing the valve is made via the switching requests Open* and Close*. The state machine of the Operation Mode manages whether and from which source new switching requests are processed.
If requests are sent simultaneously to Open* and Close*, the safety position takes precedence: SafePosEn := FALSE means the valve remains in its current state. In SafePosEn = TRUE, the valve opens when SafePos = TRUE or closes when SafePos = FALSE
If Locking is active, control of the outputs via the switching requests is prevented or the safety position is assumed.
Setpoint specification
The position is specified via Pos* variables. The position specification is managed by the state machine of the Source Mode and output according to the diagram below:

Safety position
The safety position is defined via the variables SafePosEn and SafePos .
The variable SafePosEn is used to describe whether the valve has a fixed safety position (SafePosEn = TRUE) or whether the current position should be maintained (SafePosEn = FALSE)
The safety position is described with SafePos:
SafePos = FALSE: Safety position of the valve: PosMin
SafePos = TRUE: Safety position of the valve: PosMax
Monitoring
The control and the respective Feedback can be monitored via Feedback monitoring.
The interface also has a position monitor, which extends the Feedback monitoring with 2 additional outputs:
The output PosReachedFbk indicates whether the set position has been reached:
PosReachedFbk = |PosFbk - Pos| <= PosTolerance
The time to reach the position is specified via the input MonPosTi. If the time is exceeded, the output MonPosErr is set to TRUE.
Further properties
Inheritance hierarchy
FB_MTP_AnaVlv
FB_MTP_MonAnaVlv
Implemented interfaces
 Inputs
Name | Type | Description | OPC UA access |
|---|---|---|---|
TagName | STRING | Name of the interface | - |
TagDescription | STRING | Description of the interface | - |
WQC | BYTE | Worst Quality Code | Read |
OSLevel | BYTE | Level must be defined for system. Value 0 is reserved for local operation. | Read/write |
StateChannel StateOffAut StateOpAut StateAutAut |
| See Operation Mode |
|
OpenAut | BOOL |
| Read |
CloseAut | BOOL |
| Read |
OpenFbkCaIc | BOOL | Source of the valve-open limit switch feedback signal: 1: Calculated 0: Sensor | Read |
OpenFbk | BOOL | Valve-open limit switch feedback signal | Read |
CloseFbkCaIc | BOOL | Source of the feedback signal Valve-closed limit switch: 1: Calculated 0: Sensor | Read |
CloseFbk | BOOL | Valve-closed limit switch feedback signal. | Read |
SrcChannel SrcManAut SrcIntAut |
| See Source Mode |
|
PosInt | REAL |
| Read |
PosUnit | INT | Unit of the position | Read |
PosMin | REAL | Lower limit of the value specification for the valve position | Read |
PosMax | REAL | Upper limit of the value specification for the valve position | Read |
PosFbkCaIc | BOOL | Source of the position feedback value: 1: Calculated 0: Sensor | Read |
PosFbk | REAL | Feedback value of the position | Read |
PosScIMin | REAL | Scale start of the position display | Read |
PosScIMax | REAL | Scale end of the position display | Read |
PermEn Permit IntlEn Interlock ProtEn Protect |
| See Locking |
|
SafePosEn | BOOL | Use the safe position of the valve: 1: Use safe position. 0: Do not use safe position. | Read |
SafePos | BOOL | Safe position of the valve: 1: Open 0: Closed | Read |
ResetAut | BOOL |
1: Reset requested. 0: No reset requested. | Read |
MonEn | BOOL | Enable 1: 0: | Read/write |
MonStatTi | REAL | Monitoring time for static errors [s] | Read |
MonDynTi | REAL | Monitoring time for dynamic errors [s] | Read |
MonSafePos | BOOL | Behavior of the interface after an error occurs: 1: Safe position should be approached. 0: The current state is retained. | Read |
 | It is possible to change the value of the input variable |
 Outputs
Name | Type | Description | OPC UA access |
|---|---|---|---|
StateOffAct StateOpAct StateAutAct |
| See Operation Mode |
|
OpenAct | BOOL | Open valve switching command. | Read |
CloseAct | BOOL | Close valve switching command. | Read |
SrcManAct SrcIntAct |
| See Source Mode |
|
Pos | REAL | Position setpoint on valve | Read |
SafePosAct | BOOL | Safe position: 1: Move to a safe position 0: Normal operation | Read |
MonStatErr | REAL | Static error: 1: active 0: inactive | Read |
MonDynErr | REAL | Dynamic error: 1: active 0: inactive | Read |
External variables
Name | Type | Description | OPC UA access |
|---|---|---|---|
StateOffOp StateOpOp StateAutOp |
| See Operation Mode |
|
OpenOp | BOOL |
| Read/write |
CloseOp | BOOL |
| Read/write |
SrcManOp SrcIntOp |
| See Source Mode |
|
PosMan | BOOL |
| Read/write |
PosRbk | REAL | Unprocessed value of the | Read/write |
ResetOp | BOOL |
0→1: 1→0: Request has been processed. | Read/write |
 Methods
Name | Type | Description |
|---|---|---|
IsOffline IsOperator IsAutomatic SetOffline SetOperator SetAutomatic |
| See Operation Mode |
IsInternal IsManual SetInternal SetManual |
| See Source Mode |
Open | BOOL | The For position specification, the Returns |
Close | BOOL | The For position specification, the Returns |