Basic function principles
Operation modes of the EL2522
In addition to the “extended operation mode” familiar from the EL2521, the EL2522 also supports an “extended operation mode with continuous position specification” and an “extended operation mode with continuous position specification and arrival time”.
As an extension of the EL2521, the EL2522 offers the “extended operation mode” in 1-channel or single operation mode with A, B, and C tracks (“zero track”/reference) or in 2-channel or dual operation mode with A and B tracks, respectively.
Version | PDO settings | Comments | FW/HW | ESI | Process data | CoE parameters |
|---|---|---|---|---|---|---|
Legacy | formerly MDP 252 | Not available for the EL2522 | - | - | - | - |
Enhanced operation mode | 1 Ch. Standard 16 Bit (MDP 253/511) 2 Ch. Standard 16 Bit (MDP 253/511) 1 Ch. Standard 32 Bit (MDP 253/511) 2 Ch. Standard 32 Bit (MDP 253/511) | 1 Ch.: with C‑track | from 02 | from EL2522-0000 | PDO assignment Inputs 0x1A00, 0x1A02 Outputs: 0x1600, 0x1602, 0x160A | Feature-Bits and Settings in CoE objects (hex) 8000, 8010, 8020 and 8030 |
Enhanced operation mode with continuous position specification | 1 Ch. Standard 32 Bit (MDP 253/511) 2 Ch. Standard 32 Bit (MDP 253/511) | 1 Ch.: with C-track; Travel path without ramp, DC-Synchron must be selected | from 02 | from EL2522-0000 | PDO assignment Inputs: 0x1A03 Outputs: | |
Enhanced operation mode with continuous position specification and arrival time | 1 Ch. Standard 32 Bit (MDP 253/511) 2 Ch. Standard 32 Bit (MDP 253/511) | 1 Ch.: with C‑track; Travel path without ramp, specification of arrival time possible (target time); DC-Synchron must be selected | from 02 | from EL2522-0000 | PDO assignment Inputs: 0x1A03 Outputs: |
Output modes of the EL2522
About the following indices in the CoE
the following output modes are available for choice:
- “Frequency modulation (value: 0)”,
- “Pulse direction signal (value: 1)” and
- “Incremental encoder (value: 2)”.
 | Cycle-synchronous output in operation modes with “continuous position”
|
Output modes | Meaning | Index 0x8000:0E value |
|
|---|---|---|---|
Frequency modulation | Only one channel is active in each direction at a time. A frequency-modulated signal is output on this channel. | 0 |
|
Pulse direction signal | The direction is controlled by channel B. The clockwise direction is represented by a low-level and the counter clockwise direction by a high level. The actual signal, is then output in modulated via channel A. | 1 |
|
Incremental encoders | The direction is defined by the shifting of channels A and B. If channel A leads by 90°, this indicates a “forward” movement. Channel B, which leads by 90°, in response to a “backward” movement. | 2 |
|
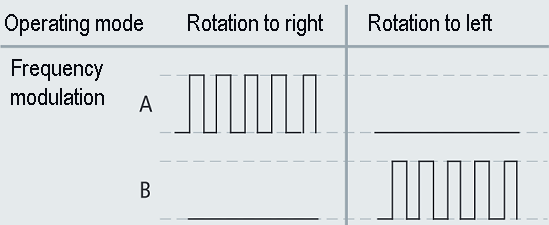
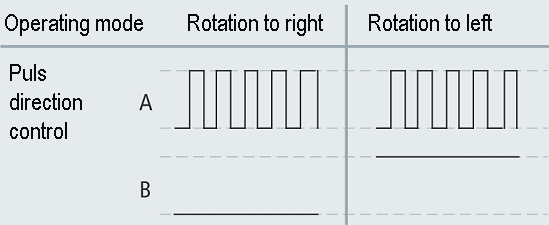
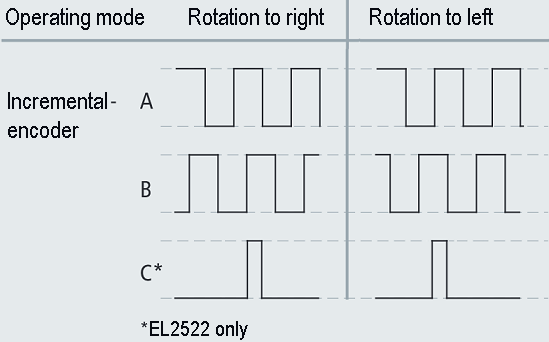
| Process data monitoring
|
Delivery state
Independent of the hardware/firmware version, an EL2522 newly integrated in the system registers itself in the operating mode “2-channel standard 32-bit (MDP 253/511)”.
Incremental encoder simulation
The “enhanced operation mode (253/511)” is the enhanced operation mode familiar from the EL2521. Please refer to the corresponding chapter of the EL2521 (see also chapter EL2521 function) for an explanation of the functionality and the steps necessary for commissioning.
Unlike the EL2521, it is possible to choose between a 1-channel and a 2-channel operation mode (single or double operation).
- In 1-channel operation mode a C-track is output in addition to the A- and B-tracks.
- In 2-channel operation mode two outputs are offered per channel, each with an A- and a B-track. Both behave in the same way as the known 1-channel operation mode.
Incremental encoder simulation with continuous position specification
In the operation modes “1 Ch. Standard 32 Bit, continues Position” and “2 Ch. Standard 32 Bit, continues Position”, the EL2522 can simulate an incremental encoder with A, B, and C tracks (1-channel or single operation mode) or two independent incremental encoders (2-channel or dual operation mode), each with A and B tracks. As previously with the EL2521 there is also a choice here between the output modes incremental encoder, frequency modulation or pulse direction control.
Basically, the clock signals are output here cycle-synchronously (necessary selection in the EL2522 DC settings: “DC-Synchron”).
After selection of the respective PDO assignment, the associated process data are represented in accordance with the following illustration.
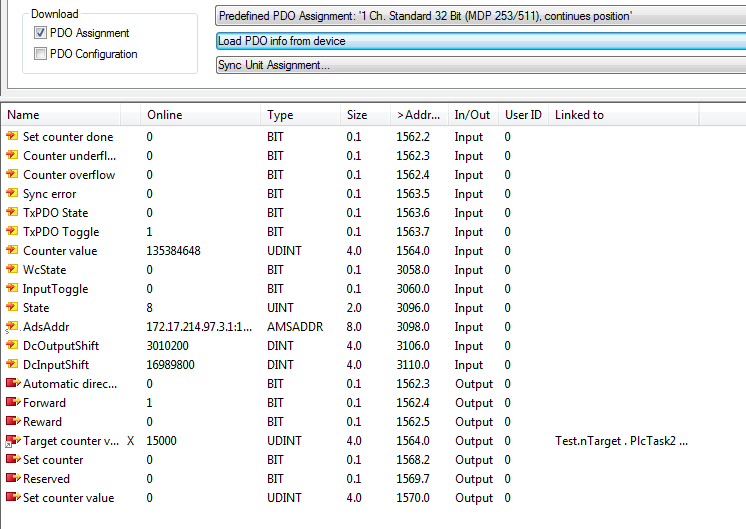
The output value “Target counter value” is written with the desired target position for the next cycle. Depending on the current position (input value “Counter value”), the EL2522 calculates the frequency necessary for reaching the desired position in the next cycle. A fixed running direction can be specified by the output bits “Forward” and “Reward”. If the “Automatic direction” bit is set, the terminal selects the running direction depending on the position difference (actual value and setpoint) in favor of the shorter distance.
If 2-channel mode is in use, the process data for the second incremental encoder are added analogously to those for the first.
Incremental encoder simulation with continuous position specification and arrival time
In addition to the functions mentioned above, it is possible in the operation mode “continuous position specification and arrival time” to define when the target position should be reached. Consequently, the calculation no longer takes place with the specification of the target position to be reached in the next cycle, but taking into account an arrival time specified by the user instead.
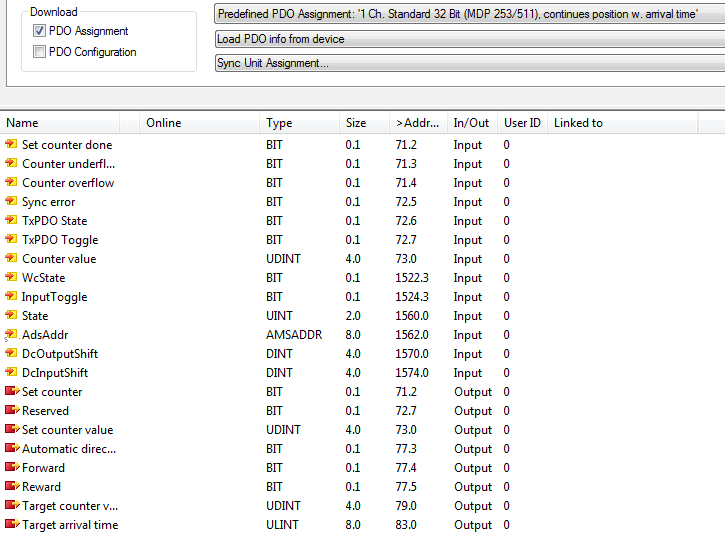
The desired target time for reaching the set position can be specified by the output value “Target arrival time”.
The frequency is then calculated accordingly. Is the
calculated frequency > Maximum frequency (0x8000:12/0x8010 “Base Frequency 1”)
=> this limits the frequency to this value, and the set position is reached later as a result.
| Use of microincrements When using microincrement values, care must be taken not to exceed the internal 100 MHz limit. Example: Cycle time 1 ms, 15-bit microincrements If three “true” increments are to be output in a cycle, this already amounts to |
| Setting the counter value / zero calibration (A/B adaptation) The counter value can be manually set.
|
Function: Automatic adoption of the setpoint
In the enhanced operation modes “continuous position specification” and “continuous position specification with arrival time”, a threshold value can be specified for the automatic adoption of setpoints. The specification is made via the CoE objects
If the difference between the setpoint and the actual value exceeds this pre-set threshold value, the actual value will be overwritten
with the setpoint on the next Sync; i.e. the value of the target counter is directly applied as the counter value without incremental encoder clock signals being output.
The following steps must be performed in order to use this function.
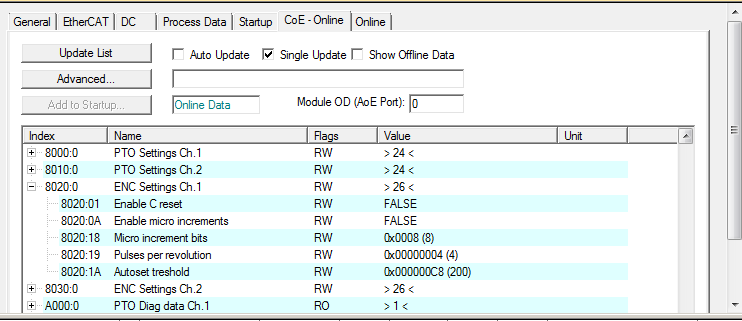
Example:
- 0x8020:1A = “Autoset threshold” = 0x00000100
- (→ the value is >=1: “Autoset treshold”, “Automatic setting” is activated)
- Cycle n (setting the target counter value):
- “Target counter value” = 0x00000200
- “Counter value” = 0x00000000
→ Threshold for automatic setting is exceeded; No clock signals will be output at the output of the terminal.
- The “Target counter value” is directly applied into the “Counter value”.
- “Target counter value” = 0x00000200
- “Counter value” = 0x00000200
- Cycle n+1 (resetting the target counter value):
- “Target counter value” = 0x00000220
- “Counter value” = 0x00000200
The threshold (0x00000100) is not overwritten with the difference between target counter value and current counter value (in this case the value: 0x20) for automatic setting. Therefore clock signals are output at the output of the terminal until the target counter value is reached.
- Cycle n+2 (continuation in this operation mode with further target counter values):
- “Target counter value” = 0x????????
- “Counter value” = 0x00000220
This function therefore allows you to set the counter value directly, as an alternative to using the 0x7020:03 (or 0x7030:03) “Set counter” object.
It is recommended to use the function of the automatic adoption of the setpoint only in special exceptional cases!
| Initialization The actual value is initialized during the transition from SafeOp to Op. The current setpoint is applied here as the actual value. |
| Exceeding the maximum frequency If the set maximum frequency is exceeded when calculating the necessary frequency for reaching the set position within the foreseen period, the maximum frequency is adopted. This leads to extended travel distances and should be taken into account and if necessary checked accordingly. The maximum frequency can be set via index 0x8010:12/0x8020:12 (Base Frequency 1). |