MC_LoadControl
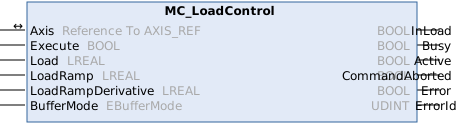
This function block continuously exerts a torque, force or pressure of the specified value.
Positive torque, force and differential pressure is in the positive direction of velocity, pressure is
physically unsigned. LoadUnit must match the unit of the value measured by the corresponding sensor.
Syntax
Definition:
FUNCTION_BLOCK MC_LoadControl
VAR_IN_OUT
    Axis               : Reference To  AXIS_REF;
END_VAR
VAR_INPUT
    Execute            : BOOL;
    Load               : LREAL;
    LoadRamp           : LREAL;
    LoadRampDerivative : LREAL;
    BufferMode         : EBufferMode;
END_VAR
VAR_OUTPUT
    InLoad             : BOOL;
    Busy               : BOOL;
    Active             : BOOL;
    CommandAborted     : BOOL;
    Error              : BOOL;
    ErrorId            : UDINT;
END_VAR
 Inputs
|
Name |
Type |
Default |
Description |
|---|---|---|---|
|
Execute |
BOOL |
|
Start the motion at rising edge. |
|
Load |
LREAL |
#Invalid |
Commanded load value ([LoadUnit]). It is approached using a defined ramp (LoadRamp). |
|
LoadRamp |
LREAL |
#Invalid |
Maximum load derivative ([LoadUnit/s], positive) |
|
LoadRampDerivative |
LREAL |
#Ignore |
Maximum load ramp derivative ([LoadUnit/s^2], positive). It can be left as 'Ignore' if no ramp derivative limit is desired. |
|
BufferMode |
Aborting |
Chronological sequence of the command |
 Outputs
|
Name |
Type |
Description |
|---|---|---|
|
InLoad |
BOOL |
Commanded load value reached |
|
Busy |
BOOL |
Function block is not finished and new output values are to be expected. |
|
Active |
BOOL |
Function block has active control on the axis. |
|
CommandAborted |
BOOL |
Command is aborted by another command. |
|
Error |
BOOL |
Error occurred within function block. |
|
ErrorId |
UDINT |
Error identifier |
Mögliche Fehlercodes
Für diesen Funktionsbaustein sind unter anderem die folgenden Werte für den Ausgang ErrorId möglich:
Fehler(Hex) | Fehler(Dez) | Fehlertyp | Beschreibung |
|---|---|---|---|
0x813c | 33084 | Parameter | Der Buffer-Modus ist ungültig. Der am Funktionsbaustein angegebene BufferMode ist unbekannt oder wird vom Kommando nicht unterstützt (einige Kommandos akzeptieren z.B. nur Aborting, andere nur Buffered). |
0x8145 | 33093 | Funktionsbaustein | Die Verknüpfung des zyklischen Interfaces zwischen NC und SPS fehlt (z.B. AXIS_REF, AXES_GROUP_REF, ...). Eine vom Funktionsbaustein verwendete Referenz (z.B. auf eine Achse, Gruppe, einen Mover oder ein anderes Motion-Objekt) ist nicht mit dem zugehörigen NC-Objekt verknüpft oder die zyklische Verknüpfung ist unvollständig. |
0x81ac | 33196 | Parameter | Ungültiger Last-Wert. Der für einen Druck- oder Kraft-Befehl angegebene Last-Wert ist ungültig (z.B. NaN oder außerhalb des erlaubten Bereichs). |
0x81ad | 33197 | Parameter | Ungültiger Last-Rampen-Wert. Der Wert der Last-Rampe (Geschwindigkeit des Last-Aufbaus) ist ungültig (z.B. kleiner oder gleich Null oder NaN). |
0x81ae | 33198 | Parameter | Ungültiger Last-Rampen-Änderungs-Wert. Die Ableitung der Last-Rampe (Änderungs-Rate des Last-Aufbaus) ist ungültig (z.B. kleiner oder gleich Null oder NaN). Der Wert ist optional und kann ungenutzt bleiben. |
Eine Übersicht aller NC-Fehlercodes finden Sie hier:
Versionsinformation
- TwinCAT Standard >= v3.1.4026.23.1
- TF5500 MC3 Base >= v4.0.6