F_VN_RotatedRectangleCorners

Computes the 4 corner points of a rotated rectangle.
Syntax
Definition:
FUNCTION F_VN_RotatedRectangleCorners : HRESULT
VAR_IN_OUT
stRect : TcVnRotatedRectangle;
aCorners : TcVnArray4_Point2_REAL;
END_VAR
VAR_INPUT
hrPrev : HRESULT;
END_VAR Inputs
Name | Type | Description |
|---|---|---|
hrPrev | HRESULT indicating the result of previous operations (If SUCCEEDED(hrPrev) equals false, no operation is executed.) |
In/Outputs
Name | Type | Description |
|---|---|---|
stRect | Rotated rectangle | |
aCorners | Returns the 4 corner points |
 Return value
Further information
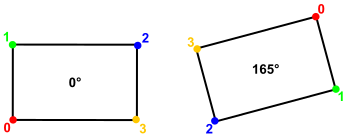
The function returns the four corners aCorners of the rotated rectangle as TcVnArray4_Point2_REAL, which corresponds to an Array [0..3] of TcVnPoint2_REAL . At an angle of 0°, aCorners[0] contains the coordinates of the lower left corner of the rectangle parallel to the axes. The remaining indices follow a clockwise order from the top left (aCorners[1]), top right (aCorners[2]), to the bottom right (aCorners[3]). If the rectangle is rotated by 165°, for example, the corner assignment rotates accordingly so that the original bottom left corner is now at the top right.
Required License
TC3 Vision Base
System Requirements
Development environment | Target platform | PLC libraries to include |
|---|---|---|
TwinCAT V3.1.4024.59 or later | PC or CX (x64) with min. PL50, e.g. Intel 4-core Atom CPU | Tc3_Vision |