MC_ValveCharacterization
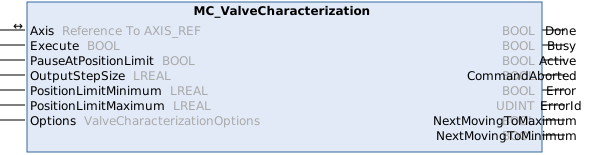
This function block characterizes the valve characteristic curve of the axis through a series of velocity measurements.
For each measurement the function block generates an output value for the drive based on the OutputStepSize input and
the drive's actuating value range and measures the resulting actual velocity.
Syntax
Definition:
FUNCTION_BLOCK MC_ValveCharacterization
VAR_IN_OUT
    Axis                 : Reference To  AXIS_REF;
END_VAR
VAR_INPUT
    Execute              : BOOL;
    PauseAtPositionLimit : BOOL;
    OutputStepSize       : LREAL;
    PositionLimitMinimum : LREAL;
    PositionLimitMaximum : LREAL;
    Options              : ValveCharacterizationOptions;
END_VAR
VAR_OUTPUT
    Done                 : BOOL;
    Busy                 : BOOL;
    Active               : BOOL;
    CommandAborted       : BOOL;
    Error                : BOOL;
    ErrorId              : UDINT;
    NextMovingToMaximum  : BOOL;
    NextMovingToMinimum  : BOOL;
END_VAR
 Inputs
|
Name |
Type |
Default |
Description |
|---|---|---|---|
|
Execute |
BOOL |
|
Start the valve characterization process at rising edge. |
|
PauseAtPositionLimit |
BOOL |
false |
The upcoming move is delayed while PauseAtPositionLimit = TRUE. |
|
OutputStepSize |
LREAL |
#Invalid |
Size of output steps. Must have value [0..1], where 1 = output value changes by 100% between two measurements (0 = no change) |
|
PositionLimitMinimum |
LREAL |
#Invalid |
Minimum position ([PosUnit]). Must have value < PositionLimitMaximum. |
|
PositionLimitMaximum |
LREAL |
#Invalid |
Maximum position ([PosUnit]). Must have value > PositionLimitMinimum. |
|
Options |
|
Additional function block options |
In/Outputs
|
Name |
Type |
Description |
|---|---|---|
|
Axis |
Reference To AXIS_REF |
Reference to the axis |
 Outputs
|
Name |
Type |
Description |
|---|---|---|
|
Done |
BOOL |
Valve characterization finished successfully |
|
Busy |
BOOL |
Function block is not finished and new output values are to be expected. |
|
Active |
BOOL |
Function block has active control on the axis. |
|
CommandAborted |
BOOL |
Command is aborted by another command. |
|
Error |
BOOL |
Error occurred within function block. |
|
ErrorId |
UDINT |
Error identifier |
|
NextMovingToMaximum |
BOOL |
Positive move upcoming |
|
NextMovingToMinimum |
BOOL |
Negative move upcoming |
Possible error codes
For this function block, the following values, among others, are possible for the ErrorId output:
Error(Hex) | Error(Dec) | Error type | Description |
|---|---|---|---|
0x8145 | 33093 | Function Block | Mapping of cyclic interface between NC and PLC is missing (e.g., AXIS_REF, AXES_GROUP_REF, ...). A reference used by the function block (e.g., to an axis, group, mover or other motion object) is not linked to the corresponding NC object, or its cyclic mapping is incomplete. |
0x8151 | 33105 | State | Command is not allowed in current axis state. If the axis has no controller enable, is in error or has been added to a group, some commands are not permitted. |
0x8196 | 33174 | Initialization | Invalid position or distance. The actual or specified position or distance could not be determined or is invalid. |
0x81a9 | 33193 | Parameter | Invalid acceleration value. The supplied acceleration value is invalid (e.g. not a finite number, negative or outside the permitted range). |
0x81aa | 33194 | Parameter | Invalid deceleration value. The supplied deceleration value is invalid (e.g. not a finite number, negative or outside the permitted range). |
0x81ab | 33195 | Parameter | Invalid jerk value. The jerk value used for the motion is invalid (e.g., negative, zero, or outside the permitted range of the mover or axis). |
0x81b7 | 33207 | Function Block | The specified time or duration is invalid. |
An overview of all NC error codes can be found here:
Version information
- TwinCAT Standard >= v3.1.4026.23.1
- TF5560 MC3 FluidPower >= v4.0.6 (includes TF5500 MC3 Base >= v4.0.6)
Required License
TC3 MC3 Fluid Power