MC_MoveModulo
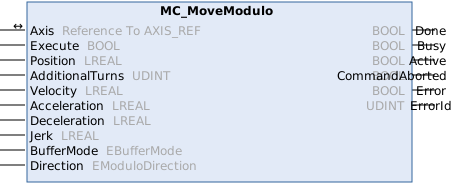
This function block commands a motion to a specified modulo position.
Syntax
Definition:
FUNCTION_BLOCK MC_MoveModulo
VAR_IN_OUT
    Axis            : Reference To  AXIS_REF;
END_VAR
VAR_INPUT
    Execute         : BOOL;
    Position        : LREAL;
    AdditionalTurns : UDINT;
    Velocity        : LREAL;
    Acceleration    : LREAL;
    Deceleration    : LREAL;
    Jerk            : LREAL;
    BufferMode      : EBufferMode;
    Direction       : EModuloDirection;
END_VAR
VAR_OUTPUT
    Done            : BOOL;
    Busy            : BOOL;
    Active          : BOOL;
    CommandAborted  : BOOL;
    Error           : BOOL;
    ErrorId         : UDINT;
END_VAR
 Inputs
|
Name |
Type |
Default |
Description |
|---|---|---|---|
|
Execute |
BOOL |
|
Trigger the command with rising edge. |
|
Position |
LREAL |
#Invalid |
Commanded modulo position ([PosUnit]) |
|
AdditionalTurns |
UDINT |
0 |
Number of additional modulo turns in the commanded direction. A value > 0 requires Direction <> EModuloDirection.ShortestDistance. |
|
Velocity |
LREAL |
#Invalid |
Maximum velocity ([PosUnit]/s, positive) |
|
Acceleration |
LREAL |
#Default |
Maximum acceleration ([PosUnit]/s^2, positive) |
|
Deceleration |
LREAL |
#Default |
Maximum deceleration ([PosUnit]/s^2, positive) |
|
Jerk |
LREAL |
#Default |
Maximum jerk ([PosUnit]/s^3, positive) |
|
BufferMode |
Aborting |
Chronological sequence of the command | |
|
Direction |
ShortestDistance |
Commanded direction. Must have value <> EModuloDirection.ShortestDistance if AdditionalTurns has value > 0. |
 Outputs
|
Name |
Type |
Description |
|---|---|---|
|
Done |
BOOL |
Commanded position finally reached |
|
Busy |
BOOL |
Function block is not finished and new output values are to be expected. |
|
Active |
BOOL |
Function block has active control on the axis. |
|
CommandAborted |
BOOL |
Command is aborted by another command. |
|
Error |
BOOL |
Error occurred within function block. |
|
ErrorId |
UDINT |
Error identifier |
Further information
If the Direction input is set to PositiveDirection or NegativeDirection, the AdditionalTurns input is also taken into account. The AdditionalTurns input can be used to specify additional turns until the target position is reached.
Further information on Modulo positioning.
Possible error codes
For this function block, the following values, among others, are possible for the ErrorId output:
Error(Hex) | Error(Dec) | Error type | Description |
|---|---|---|---|
0x813c | 33084 | Parameter | BufferMode is invalid. The BufferMode passed to the function block is unknown or not supported by the command (some commands accept only Aborting, others only Buffered). |
0x8145 | 33093 | Function Block | Mapping of cyclic interface between NC and PLC is missing (e.g., AXIS_REF, AXES_GROUP_REF, ...). A reference used by the function block (e.g., to an axis, group, mover or other motion object) is not linked to the corresponding NC object, or its cyclic mapping is incomplete. |
0x8146 | 33094 | Function Block | Invalid velocity value. The velocity was not set or the entered value is invalid. |
0x8151 | 33105 | State | Command is not allowed in current axis state. If the axis has no controller enable, is in error or has been added to a group, some commands are not permitted. |
0x8182 | 33154 | Monitoring | Software position limit violation. Software position limits of at least one axis have been or would have been violated by a command. |
0x818c | 33164 | Parameter | Position is out of modulo range. Position must be larger or equal to zero and less or equal to the modulus when using modulo positioning. When using modulo positioning, the target position is interpreted in consideration of the AdditionalTurns variable at the Options input. |
0x818d | 33165 | Parameter | The specified value AdditionalTurns at the Options input is not allowed. The parameter AdditionalTurns must be zero for the specified value of the parameter direction. |
0x8196 | 33174 | Initialization | Invalid position or distance. The actual or specified position or distance could not be determined or is invalid. |
0x819a | 33178 | NC Programming | Direction-dependent feed enable is missing. The execution of this command is not possible because of a missing direction-dependent feed enable. |
0x819b | 33179 | NC Programming | Controller enable is missing. The controller enable of the axis was withdrawn during a movement. The dynamics of the setpoint did not correspond to zero dynamics. |
0x81a9 | 33193 | Parameter | Invalid acceleration value. The supplied acceleration value is invalid (e.g. not a finite number, negative or outside the permitted range). |
0x81aa | 33194 | Parameter | Invalid deceleration value. The supplied deceleration value is invalid (e.g. not a finite number, negative or outside the permitted range). |
0x81ab | 33195 | Parameter | Invalid jerk value. The jerk value used for the motion is invalid (e.g., negative, zero, or outside the permitted range of the mover or axis). |
0x81bc | 33212 | Function Block | Axis is not configured as modulo axis. The command requires a modulo axis, but the axis is not configured as a modulo axis. |
An overview of all NC error codes can be found here:
Version information
- TwinCAT Standard >= v3.1.4026.23.1
- TF5500 MC3 Base >= v4.0.6