MC_LoadControl
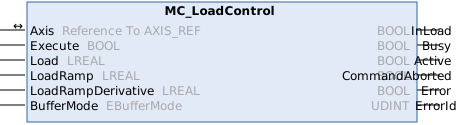
This function block continuously exerts a torque, force or pressure of the specified value.
Positive torque, force and differential pressure is in the positive direction of velocity, pressure is
physically unsigned. LoadUnit must match the unit of the value measured by the corresponding sensor.
Syntax
Definition:
FUNCTION_BLOCK MC_LoadControl
VAR_IN_OUT
    Axis               : Reference To  AXIS_REF;
END_VAR
VAR_INPUT
    Execute            : BOOL;
    Load               : LREAL;
    LoadRamp           : LREAL;
    LoadRampDerivative : LREAL;
    BufferMode         : EBufferMode;
END_VAR
VAR_OUTPUT
    InLoad             : BOOL;
    Busy               : BOOL;
    Active             : BOOL;
    CommandAborted     : BOOL;
    Error              : BOOL;
    ErrorId            : UDINT;
END_VAR
 Inputs
|
Name |
Type |
Default |
Description |
|---|---|---|---|
|
Execute |
BOOL |
|
Start the motion at rising edge. |
|
Load |
LREAL |
#Invalid |
Commanded load value ([LoadUnit]). It is approached using a defined ramp (LoadRamp). |
|
LoadRamp |
LREAL |
#Invalid |
Maximum load derivative ([LoadUnit/s], positive) |
|
LoadRampDerivative |
LREAL |
#Ignore |
Maximum load ramp derivative ([LoadUnit/s^2], positive). It can be left as 'Ignore' if no ramp derivative limit is desired. |
|
BufferMode |
Aborting |
Chronological sequence of the command |
 Outputs
|
Name |
Type |
Description |
|---|---|---|
|
InLoad |
BOOL |
Commanded load value reached |
|
Busy |
BOOL |
Function block is not finished and new output values are to be expected. |
|
Active |
BOOL |
Function block has active control on the axis. |
|
CommandAborted |
BOOL |
Command is aborted by another command. |
|
Error |
BOOL |
Error occurred within function block. |
|
ErrorId |
UDINT |
Error identifier |
Possible error codes
For this function block, the following values, among others, are possible for the ErrorId output:
Error(Hex) | Error(Dec) | Error type | Description |
|---|---|---|---|
0x813c | 33084 | Parameter | BufferMode is invalid. The BufferMode passed to the function block is unknown or not supported by the command (some commands accept only Aborting, others only Buffered). |
0x8145 | 33093 | Function Block | Mapping of cyclic interface between NC and PLC is missing (e.g., AXIS_REF, AXES_GROUP_REF, ...). A reference used by the function block (e.g., to an axis, group, mover or other motion object) is not linked to the corresponding NC object, or its cyclic mapping is incomplete. |
0x81ac | 33196 | Parameter | Invalid load value. The load value specified for a pressure or force command is invalid (e.g., NaN or outside the permitted range). |
0x81ad | 33197 | Parameter | Invalid load ramp value. The load ramp value (rate of load build-up) is invalid (e.g., less than or equal to zero or NaN). |
0x81ae | 33198 | Parameter | Invalid load ramp derivative value. The load ramp derivative (rate of change of the load build-up) is invalid (e.g., less than or equal to zero or NaN). The value is optional and may be left unused. |
An overview of all NC error codes can be found here:
Version information
- TwinCAT Standard >= v3.1.4026.23.1
- TF5500 MC3 Base >= v4.0.6