MC_HaltPhasing
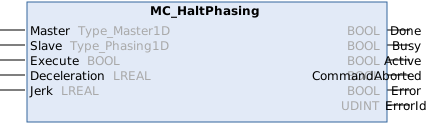
This function block commands a phase shift stop in the master position of a synchronized slave axis. It is only valid for camming synchronization. The master axis is not aware of the phase shift.
Syntax
Definition:
FUNCTION_BLOCK MC_HaltPhasing
VAR_INPUT
    Master         : Type_Master1D;
    Slave          : Type_Phasing1D;
    Execute        : BOOL;
    Deceleration   : LREAL;
    Jerk           : LREAL;
END_VAR
VAR_OUTPUT
    Done           : BOOL;
    Busy           : BOOL;
    Active         : BOOL;
    CommandAborted : BOOL;
    Error          : BOOL;
    ErrorId        : UDINT;
END_VAR
 Inputs
|
Name |
Type |
Default |
Description |
|---|---|---|---|
|
Master |
|
Reference to the master axis | |
|
Slave |
|
Reference to the slave axis | |
|
Execute |
BOOL |
|
Trigger the command with rising edge. |
|
Deceleration |
LREAL |
#Invalid |
Maximum deceleration ([PosUnit]/s^2, positive) |
|
Jerk |
LREAL |
#Invalid |
Maximum jerk ([PosUnit]/s^3, positive) |
 Outputs
|
Name |
Type |
Description |
|---|---|---|
|
Done |
BOOL |
Zero dynamics has been reached, axis state is transferred to Standstill. |
|
Busy |
BOOL |
Function block is not finished and new output values are to be expected. |
|
Active |
BOOL |
Function block has active control on the axis. |
|
CommandAborted |
BOOL |
Command is aborted by another command. |
|
Error |
BOOL |
Error occurred within function block. |
|
ErrorId |
UDINT |
Error identifier |
Possible error codes
For this function block, the following values, among others, are possible for the ErrorId output:
Error(Hex) | Error(Dec) | Error type | Description |
|---|---|---|---|
0x8145 | 33093 | Function Block | Mapping of cyclic interface between NC and PLC is missing (e.g., AXIS_REF, AXES_GROUP_REF, ...). A reference used by the function block (e.g., to an axis, group, mover or other motion object) is not linked to the corresponding NC object, or its cyclic mapping is incomplete. |
0x8151 | 33105 | State | Command is not allowed in current axis state. If the axis has no controller enable, is in error or has been added to a group, some commands are not permitted. |
0x81aa | 33194 | Parameter | Invalid deceleration value. The supplied deceleration value is invalid (e.g. not a finite number, negative or outside the permitted range). |
0x81ab | 33195 | Parameter | Invalid jerk value. The jerk value used for the motion is invalid (e.g., negative, zero, or outside the permitted range of the mover or axis). |
An overview of all NC error codes can be found here:
Version information
- TwinCAT Standard >= v3.1.4026.23.1
- TF5500 MC3 Base >= v4.0.6