MC_Halt
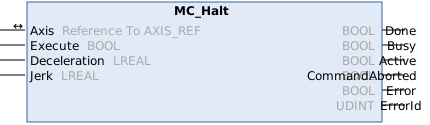
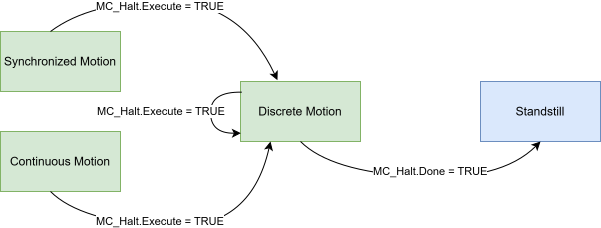
This function block commands a motion stop. The axis is transferred to the state DiscreteMotion, until zero dynamics is reached.
Syntax
Definition:
FUNCTION_BLOCK MC_Halt
VAR_IN_OUT
    Axis           : Reference To  AXIS_REF;
END_VAR
VAR_INPUT
    Execute        : BOOL;
    Deceleration   : LREAL;
    Jerk           : LREAL;
END_VAR
VAR_OUTPUT
    Done           : BOOL;
    Busy           : BOOL;
    Active         : BOOL;
    CommandAborted : BOOL;
    Error          : BOOL;
    ErrorId        : UDINT;
END_VAR
 Inputs
|
Name |
Type |
Default |
Description |
|---|---|---|---|
|
Execute |
BOOL |
|
Trigger the command with rising edge. |
|
Deceleration |
LREAL |
#Default |
Maximum deceleration ([PosUnit]/s^2, positive) |
|
Jerk |
LREAL |
#Default |
Maximum jerk ([PosUnit]/s^3, positive) |
 Outputs
|
Name |
Type |
Description |
|---|---|---|
|
Done |
BOOL |
Zero dynamics has been reached, axis state is transferred to Standstill. |
|
Busy |
BOOL |
Function block is not finished and new output values are to be expected. |
|
Active |
BOOL |
Function block has active control on the axis. |
|
CommandAborted |
BOOL |
Command is aborted by another command. |
|
Error |
BOOL |
Error occurred within function block. |
|
ErrorId |
UDINT |
Error identifier |
Further information
The function block MC_Halt is used to stop an axis with a defined deceleration ramp.
Unlike MC_Stop, the axis is not locked against further motion commands. This means that the MC_Halt command can be canceled either during the motion ramp or immediately afterward by another motion command.
If MC_Halt is applied to a coupled slave axis, the axis is automatically decoupled, and the halt command is then executed.
Effects on the axis state
Note on the migration from NC2 to MC3
Unlike the NC2 function block of the same name, the MC3 function block MC_Halt does not have an input that can be used to set the buffer mode. In MC3, any previous command is always aborted immediately by MC_Halt, which internally corresponds to the Aborting buffer mode.
In MC3, the parameterization of the dynamics is not possible with a value of 0 (implicit use of the last commanded dynamics).
Possible error codes
For this function block, the following values, among others, are possible for the ErrorId output:
Error(Hex) | Error(Dec) | Error type | Description |
|---|---|---|---|
0x8145 | 33093 | Function Block | Mapping of cyclic interface between NC and PLC is missing (e.g., AXIS_REF, AXES_GROUP_REF, ...). A reference used by the function block (e.g., to an axis, group, mover or other motion object) is not linked to the corresponding NC object, or its cyclic mapping is incomplete. |
0x8151 | 33105 | State | Command is not allowed in current axis state. If the axis has no controller enable, is in error or has been added to a group, some commands are not permitted. |
0x81aa | 33194 | Parameter | Invalid deceleration value. The supplied deceleration value is invalid (e.g. not a finite number, negative or outside the permitted range). |
0x81ab | 33195 | Parameter | Invalid jerk value. The jerk value used for the motion is invalid (e.g., negative, zero, or outside the permitted range of the mover or axis). |
An overview of all NC error codes can be found here:
Version information
- TwinCAT Standard >= v3.1.4026.23.1
- TF5500 MC3 Base >= v4.0.6