MC_ReadStopInfo
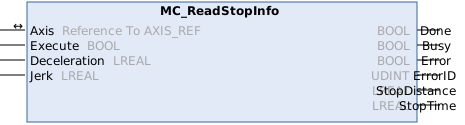
The MC_ReadStopInfo function block can be used to calculate the distance and time to a complete stop of the axis, based on the specified dynamics.
It should be noted that while the calculated values provide an estimate, the actual distance and time to a standstill may differ from these values due to ADS runtimes, depending on the prevailing dynamics.
 Inputs
VAR_INPUT
    Execute           : BOOL;
    Deceleration      : LREAL;
    Jerk              : LREAL;
END_VAR
Name | Type | Description |
|---|---|---|
Execute | BOOL | The command is executed with a rising edge. |
Deceleration | LREAL | Deceleration (≥0) If the value is 0, the default deceleration from the axis configuration is applied. |
Jerk | LREAL | Jerk (≥0) If the value is 0, the default jerk from the axis configuration is applied. |
 Inputs/outputs
VAR_IN_OUT
    Axis : AXIS_REF;
END_VAR
Name | Type | Description |
|---|---|---|
Axis | Axis data structure that unambiguously addresses an axis in the system. Among other parameters it contains the current axis status, including position, velocity or error state. |
 Outputs
VAR_OUTPUT
    BitValues         : DWORD;
    Done              : BOOL;
    Busy              : BOOL;
    Error             : BOOL;
    ErrorID           : UDINT;
END_VAR
Name | Type | Description |
|---|---|---|
BitValues | DWORD | Values of the corresponding read bits. |
Done | BOOL | TRUE if the command was executed without errors. |
Busy | BOOL | TRUE as soon as the command is started with Execute and as long as the command is processed. If "Busy" is FALSE, the function block is ready for a new order. |
Error | BOOL | TRUE, if an error occurs. |
ErrorID | UDINT | If the error output is set, this parameter supplies the error number. |
StopDistance | LREAL | Distance until the axle comes to a stop |
StopTime | LREAL | Time to axle stop [s] |
Requirements
Development environment | Target platform | PLC library to include |
|---|---|---|
TwinCAT v3.1.4024.79 TwinCAT v3.1.4026 TF5000.NCPTP.XAE 1.0.11 | PC oder CX (x86) | Tc2_MC2 v3.3.75 |