Diagnosis of the Sync Unit
The individual servo drives should be consolidated in meaningful groups, depending on the application. Each of these groups is allocated to a Sync Unit. Since each group has its own working counter, the individual groups can continue to operate independently in the event of fatal errors. For particularly critical applications, each AX5000 can be allocated a separate Sync Unit. However, this step should only be implemented in cases where it is actually required, because each further Sync Unit results in additional data traffic on the EtherCAT segment.
Assignment of servo drives to a Sync Unit
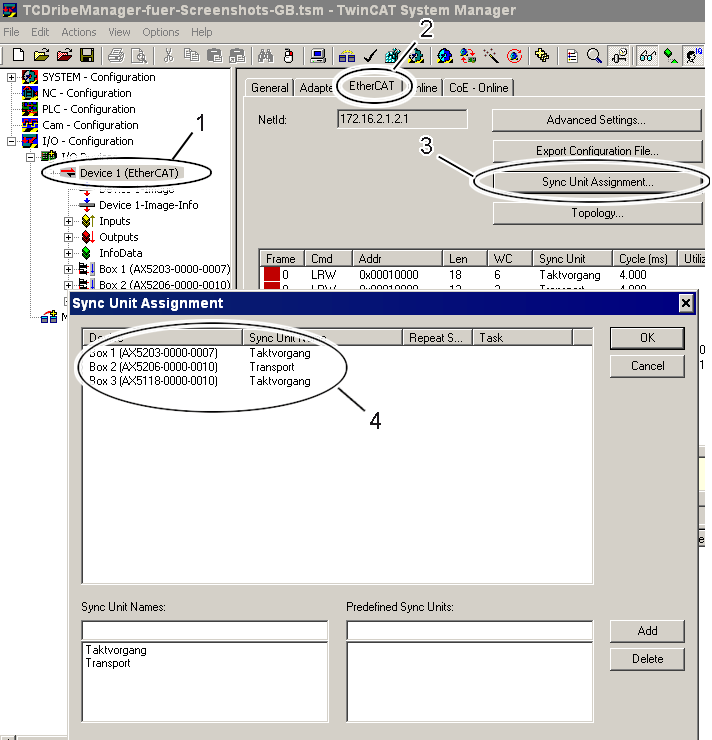
Start the TwinCAT System Manager and left-click on the associated EtherCAT segment (1). Select the “EtherCAT” tab (2) and left-click on “Sync Unit Assignment” (3). The “Sync Unit Assignment” submenu appears. Section (4) shows the servo drives and their allocation to the Sync Units. Servo drives AX5203 and AX5118 belong to Sync Unit “Cycle Process”, 5206 belongs to Sync Unit “Transport”.